Isabella Wu builds robots that sense the physical world

Computer Engineering & CS at USC · robotics and embedded systems, plus the developer tools I build along the way

Choose a door
Door 1
For developer-tool and infrastructure teams

Developer tools.

Tools that grew out of my robotics work: memory and companions for coding agents, LLM infrastructure, command-line tools, and my open-source contributions.

cd ./tools →
Door 2
For research labs, graduate programs, engineering roles

Academic.

A CV of my work with USC's underwater vehicle team, the Rocket Propulsion Lab, and the RoboLand research lab, plus hardware projects and coursework.

Read the CV →
Door 3
For game studios and creative teams

Games.

Games, AI visuals, music, and fun side projects, with a 3D harbor you can sail between them.

Set sail →
Or keep scrolling for the whole story: from the seafloor to the launch pad ↓
Tip: press 1 2 or 3 to choose. GitHub · All projects
Computer Engineering + CS · USC

Isabella Wu
builds machines that sense the world.

From the seafloor to the launch pad. I build robotics, embedded systems, and localization, plus the local-first software that makes complex hardware fast, private, and usable.

01

Between hardware and software

// who
Coding, soldering, and building robots

I study Computer Engineering & Computer Science at USC (B.S. expected December 2027), working across the full stack of physical computing, from low-level firmware and sensor fusion up to the interfaces that make complex systems usable.

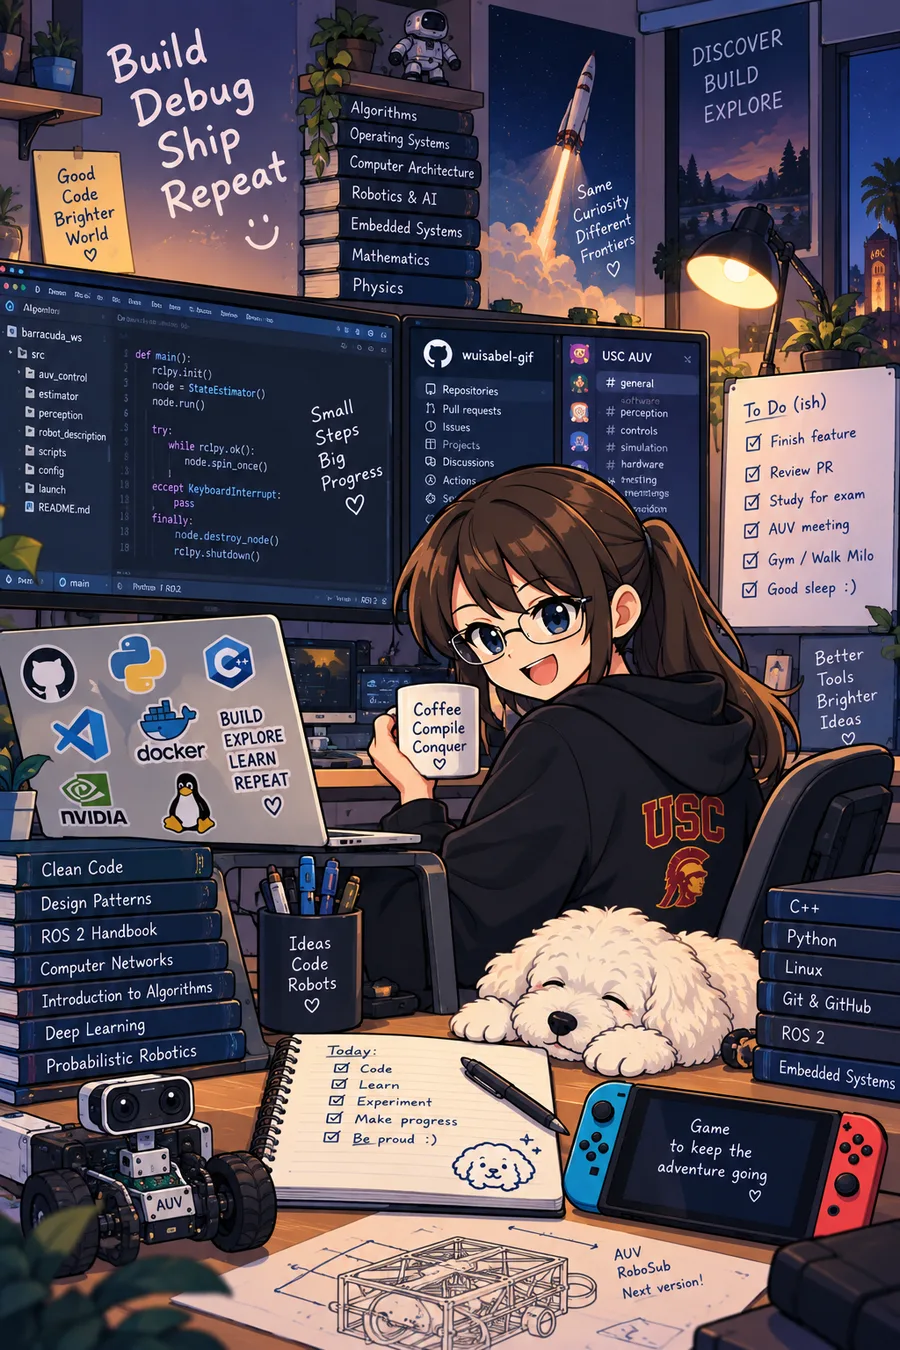
At USC I contribute to both the Autonomous Underwater Vehicle Team and the Rocket Propulsion Lab, building localization, telemetry, and sensor-driven systems for demanding real-world environments.

A lot of my work starts with a problem I hit in my own workflow and grows into a self-contained tool other people can use, like an in-browser ROS 2 bag converter or an Allan-variance IMU analyzer. The idea is taking something low-level and hard to reach and making it fast, private, and accessible. Music and literature keep finding their way in, too.

Program
Computer Eng. + CS USC
Operating range
Seafloor → Launch pad
Focus
SLAM · Embedded + tools
Off the clock
Music & Literature
02

Lab

// teams & research
Software Co-Lead · since April 2026

USC AUV Team

Barracuda AUV · Underwater SLAM & Localization · ROS 2 · GTSAM

I co-lead software for the team's Barracuda vehicle. I architected its ROS 2 / GTSAM 6-DoF state estimator, fusing IMU, DVL, depth, and ZED point clouds, and rebuilt the ICP front end with KD-tree search, estimator-predicted warm starts, and quality gates. The vehicle itself is a whole-team build.

GTSAM
factor graph
Pose3
estimation
ROS 2 · Python
stack
Embedded Software Developer · core avionics

Rocket Propulsion Lab

Flight Sensor & Telemetry Avionics · C++ · STM32 · Private repo

Co-developed a non-blocking DMA acquisition pipeline for the ADS131 ADC on STM32 and wrote SPI drivers for two vibration sensors. I led board bring-up over SWD and moved telemetry from UART to USB 2.0 links.

C++
framework
High-speed
comms
Telemetry
pipeline
Undergraduate research · CURVE Fellow

Feifei Qian Lab · RoboLand

Robot–terrain interaction · Granular physics · Python

Built a pipeline that turns 300+ robot force logs into ground-truth sand-resistance coefficients, giving the lab an independent check of its terrain model. Along the way, found a clock mismatch that ran filters 1.9× too long and a start-up transient that flipped force signs.

Granular media
terrain
Signal processing
force data
Python
pipeline
03

Selected work

// robotics first, then tools
Developer tools I'm building now
05

Open source & community

// contributions
● Community work

I work on the harness around the model

Inference engines, local serving, agent harnesses, and evaluation. Across all of them, the contributions I like best reduce friction for maintainers: closing a security hole, turning a confusing failure into a clear error, making a flaky path reliable.

rho ↗16 merged
Lightweight Rust agent harness
Hardened the harness across releases: provider error classification and retries for Anthropic and Gemini, TUI and clipboard robustness, safer tool execution (bounded timeouts, byte-safe truncation), and concurrent-approval deduplication.
Jan ↗3 merged
Offline, open-source LLM assistant
Contributed three upstream Jan fixes: securing 0.0.0.0 bindings with the Trusted Hosts allowlist (#8506), adding Azure Base URL configuration (#8510), and warning about unauthenticated public API exposure (#8532).
LocalAI ↗1 merged
Self-hosted, OpenAI-compatible inference server
Fixed a remote-code-execution risk by disabling inline GRPO reward-code execution by default.
Rerun ↗1 merged
Visualization SDK for multimodal and robotics data
Replaced a confusing failure with a clear error when a glTF/GLB asset requires an unsupported extension.
CodeWhale ↗14 merged
Rust terminal coding agent
Fixed async synchronization and event-ordering races, added per-model-call token and cache observability, and migrated runtime maps to parking_lot mutexes.
petal ↗2 merged
ROS2 Python dependency manager
Located the agent skill correctly for editable installs, and stopped unresolvable dependencies from being written to petal.toml.
Mbed CE ↗3 merged
Community edition of the Mbed OS embedded RTOS
Added NUCLEO_H753ZI target support, enabled UART FIFO mode on supported STM32 parts, and fixed zero-size realloc under heap stats.
hflow ↗2 merged
Data-quality SDK for robotics teams
Made the CLI self-describing: help text for the runtime, dataset, export, and serve commands.
Cross-platform inference engine
Added GRU operator support to the WebGPU execution provider, extending GPU inference to recurrent models.
RocketPy ↗2 merged
Rocket flight simulator
Fixed a late-starting thrust curve that kept rockets on the rail, and a flaky off-screen rendering crash in CI.
Community Proton build for Linux gaming
Fixed a NULL-caption crash in the Star Citizen message-box hook.
Modly ↗1 merged
Open-source image-to-3D tool
Wrote the headless Jetson AGX Orin deployment guide.
In flight · open pull requests under review, not yet merged
06

The toolkit

// skills
07

Off the engineering clock

// music · literature · movement
Yoga, literature, and music: life off the engineering clock

Curiosity is a whole-person thing.

I think being a full human means keeping your curiosity wide and your respect for every discipline intact, not only the ones you're paid for. Mine runs deepest toward music and literature.

I love writing and literature. I love music just as much: I've played in the SMC and USC Symphony Orchestras, and I still take cello at USC. Cello taught me discipline, and how to keep practicing when you can't see the results yet. I'm a fan of hot yoga, too.

Read more →
Let's build something

Systems, stories,
or a good idea?